Karma PDF summary. They’ve got chemistry. But he’s her brother’s worst enemy—and arresting officer.
For Officer Dare Barron, there’s only one good thing about bad-boy Brian McKnight getting thrown in the drunk tank again. Being there when Brian’s sister, Liza, strides into the precinct on those long, delectable legs to bail her brother out.
It’s not just the old building’s failing air conditioning making Dare sweat. Liza is a contradiction of proper lady and sexy siren who’s riveted Dare’s attention since high school.
She’s always been oblivious, which is a good thing because she’s way out of his league. Plus, she’s got a huge blind spot where her brother’s concerned, and Dare knows what’s hiding in that void she refuses to see.
When one of those secrets threatens Liza’s safety, Dare doesn’t hesitate to appoint himself her protector. Close proximity awakens Liza’s desire for the sexy cop and fuels the sizzling heat between them, but the bad blood between their families could ruin any chance for love.
Note: Karma is book five of Serendipity series by NYT bestselling author Carly Phillips. Contains a by-the-book cop with some hot off-shift fantasies about the girl of his dreams, and a woman who doesn’t quite mind being looked at like she’s a hot fudge sundae.
Product Details
ISBN-13: 9781685590987 Publisher: CP Publishing LLC Publication date: 06/30/2023 Series: The Serendipity Series , #5 Pages: 500 Sales rank: 140,324 Product dimensions: 5.00(w) x 8.00(h) x 1.01(d) Related Subjects
You can get the full details off this post in the link below:
I was the mistake. A piece of trash. No one wanted me. All of my life I’d been told this. I meant nothing. I was nothing.
The Volkov Bratva made a mistake. They kidnapped me and it should have been my sister. My father wanted me dead. I expected Ivan Volkov to kill me. Instead, they killed my father, and now I’m to marry Ive Yahantov, a brigadier. I’m to be his wife. The man hates me. He doesn’t want me.
I don’t know what changes, but I go from being ignored, to being with Ive all the time. We share everything. The life I thought was only ever going to be that of a dream, becomes my reality. I’m falling for the man I thought I would hate. But nothing is ever certain. Ivan Volkov faked his death, and the repercussions of that is far and wide. My husband has enemies, and those enemies, they’ve come to collect.
I knew I was going to die young, but I had no idea life could be so cruel. I knew peace. I knew love. I knew happiness, and now, it was all going to be taken away.
Product Details
BN ID: 2940166071309 Publisher: Evernight Publication date: 07/04/2023 Series: Volkov Bratva Sold by: Smashwords Format: eBook Sales rank: 224 File size: 972 KB Age Range: 18 Years
You can get the full details of this post in the link below:
Blood Vow PDF Summary. For Elise, who lost her first cousin to a grisly murder, Axe’s dangerous appeal is enticing—and possibly a distraction from her grief. But as they delve deeper into her cousin’s death, and their physical connection grows into so much more, Axe fears that the secrets he keeps and his tortured conscience will tear them apart.
Rhage, the Brother with the biggest heart, knows all about self-punishing, and he wants to help Axe reach his full potential. But when an unexpected arrival threatens Rhage and Mary’s new family, he finds himself back in the trenches again, fighting against a destiny that will destroy all he holds most dear.
As Axe’s past becomes known, and fate seems to be turning against Rhage, both males must reach deep—and pray that love, rather than anger, will be their lantern in the darkness.
Praise for Blood Vow
“Sharp, sexy, and funny.”—New York Journal of Books
“Nonstop action, steamy sexual tension . . . and absorbing characters.”—BookPage
“Packed with quietly gut-wrenching emotions, healing and sacrifice.”—Under the Covers
Praise for J. R. Ward’s Black Dagger Brotherhood series
“Utterly absorbing.”—Angela Knight
“To die for . . . I love this series!”—Suzanne Brockmann
Product Details
ISBN-13: 9780425286562 Publisher: Random House Publishing Group Publication date: 05/23/2017
Series: Black Dagger Legacy Series , #2 Pages: 480 Sales rank: 102,683 Product dimensions: 4.10(w) x 7.00(h) x 0.90(d)
You can get the full post of this in the link below:
Does It Hurt? PDF Summary. Who am i? I’ve forgotten the answer to that question long ago. Ever since I ran from that house, so desperate to escape, I left with only the clothes on my back and socks on my feet. After that day, I’ve only ever walked in stolen shoes.
Could I be a girl who is searching for the meaning of life in faceless men? They were all so forgettable. Until he came along. He took me under a waterfall and made me forget my name, and in return, I took his instead.
Enzo Vitale.
An enigmatic man that will only ever love the deep sea. Or rather the predators that inhabit it. Turns out, he’s not so different than the monsters he feeds. He lured me onto his boat like a fish in the ocean, seeking vengeance for my crime. Had I realized his intentions, and that a massive storm would leave us shipwrecked, I would’ve run.
Now, I’m a girl who’s seeking refuge in a decrepit lighthouse with a man who loathes me almost as much as he craves me. He wants to hurt me, but the old caretaker of the abandoned island may have intentions far more sinister.
It’s no longer a question of who I am, but rather, will I survive?
Product Details
ISBN-13: 9781957635033 Publisher: Hailey Carlton Publication date: 07/21/2022 Pages: 430 Sales rank: 272 Product dimensions: 5.40(w) x 8.40(h) x 1.10(d
You can get the full details of this post in the link below:
His enemy’s little sister is the only person with the power to undo him.
Nothing rattles stone-cold FBI Agent Kai Roman. Not chasing down ruthless criminals. Not losing his wife years ago. Not even inadvertently being caught in the middle of a bank robbery.
Except Camila Garza is right beside him when danger strikes, and suddenly he’s the only person who can protect the off-limits beauty. No matter how much her older brother hates him.
And no matter how much he secretly wants her.
Camila knows she should hate Roman. He’s made it clear he doesn’t like her—or possibly anyone—one bit. But when they have to go on the run to save their lives, she begins to see past his icy exterior to the man who would do anything to keep her safe.
Including risk it all.
The Agent is the sixth and last standalone in the Intelligence Unit series, set in the shared world of Remington. Full of edge-of-your-seat action and scorching romance, this adversary’s little sister, grumpy hero, lovers on the run from danger romance will have you swooning and sweating. No cheating, no cliffhangers, all hard-fought HEA.
Product Details
BN ID: 2940185832530 Publisher: Kimberly Kincaid Romance Publication date: 07/11/2023 Series: Intelligence Unit Sold by: Barnes & Noble
You can get the full details of this post in the link below:
This is “Hooked”, PDF summary Review. It is a dark romance based on Captain Hook has a delightfully wicked quality to it. The classic villain from Peter Pan is updated in Emily McIntire’s novel Hooked. McIntire’s tale will hook you with its hot plot and lovable characters.
Introducing a dark and delectable fragmented fairy tale retelling of Peter Pan from BookTok sensation Emily McIntire. He seeks retribution, but he really wants her.
James has always had one goal in mind: to eliminate Peter Michaels, his adversary. He finds his way in when Wendy, Peter’s daughter who is twenty years old, enters James’s pub. seduce the young woman and use her as his retaliation. The concept is ideal up until James’ company starts to fall apart. Suddenly, he must uncover the traitor hiding among them and devise a plan of retaliation.
becomes increasingly complicated as Wendy begins to become more than just a pawn in James’ game.
Wendy has spent the majority of her childhood in isolation due to her affluent and chilly father, but a chance encounter with James on a night out with friends leads to a passionate and compulsive romance. Wendy is unable to overcome her attraction for James despite the fact that she is aware of how dangerous he is. She isn’t sure if she’s falling for the man known as James or the monster known as Hook, though, as their relationship heats up and she learns more about the world he lives in.
Product Details
ISBN-13: 9781737508373 Publisher: Sourcebooks Publication date: 09/07/2021 Series: Never After Series , #1 Pages: 352 Sales rank: 61 Product dimensions: 5.50(w) x 8.40(h) x 1.00(d)
About the Author
Emily McIntire is an Amazon top 20 author of painful, messy, beautiful romance. She doesn’t like to box herself into one subgenre, but at the core of all her stories is soul deep love. A long time songwriter and an avid reader, Emily has always had a passion for the written word, and when she’s not writing you can find her waiting on her long lost Hogwarts letter, chasing her crazy toddler, or lost between the pages of a good book.
You can get the full details of this post in the line below:
Today’s post is about Kylian Mbappe Transfer window, there has been a controversy about the world best football player’s decision about staying at PSG or leaving the club for good when his 12 months remaining contract runs out.
In the words of Nasir Al khaleif, “Our position is very clear. If Mbappé wants to stay, we want him to stay, but he must sign a new contract. We can’t let him go free. He’s not thinking of walking away for free. If someone has changed his mind, it’s not our fault.” Said the PSG president.
The president of Paris Saint-Germain finally made the club’s intention known to Kylian Mbappe amid the brewing fire in the dressing room about their most prized player.
It has been rumoured that the favorite club to sign the player is Real Madrid. The Spanish team is said to be the French forward preferred destination. But can they risk to have him this summer; For this to be, they will have to pay at least 350 million Euros for the player, (this is about 380 million in dollars). A sum Real Madrid doesn’t seem able to afford, as sources say they have 250 million Euros designated for him, which is a total 272 million dollars in all.
However, the biggest hurdle is that the player wants to be compensated with around 100 million dollars as a signing bonus. And as mentioned above Al-Khelafi is looking to get money for the player, something Los Blancos can’t afford.
Conclusion
It is left to see from the reminder of the transfer window who the winner and loser from these war would be. What will become of Kylian Mbappe transfer?
Will it be PSG? Will it be Real Madrid? Will it be the Qatari’s who have been eyeing the young player for quite some time now? Or the Player himself?
Be a part of this by leaving us a comment below. Thank you.
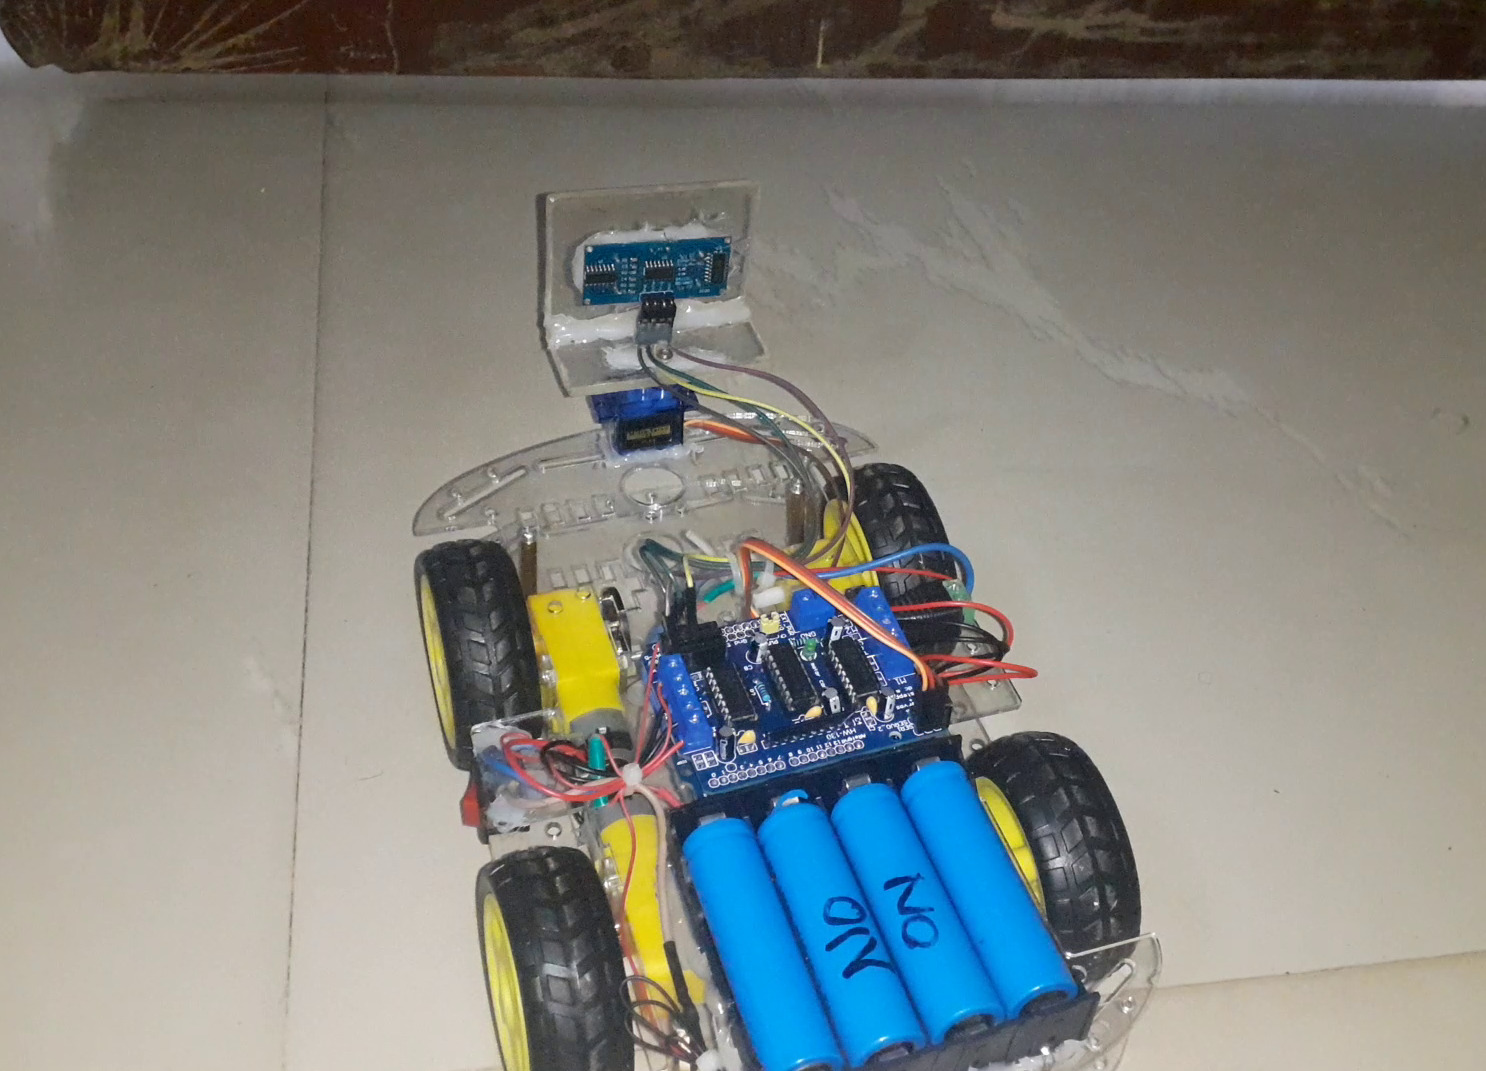
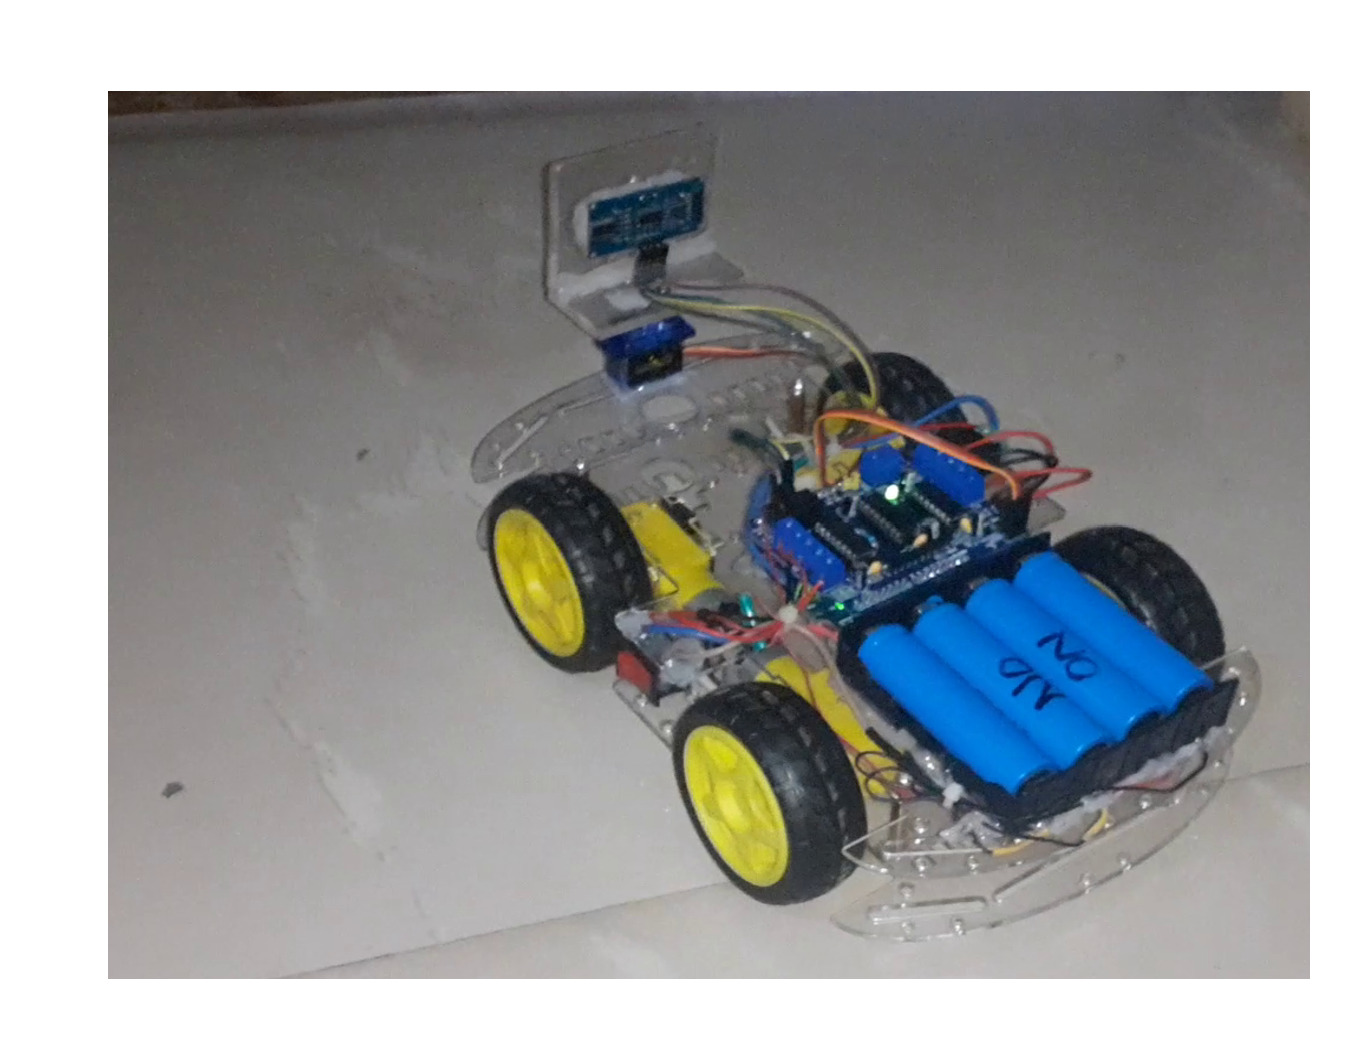
This blog post is about the design and construction of an obstacle avoidance robot that can detect obstacles in its path and find its way around it. This design is done with Arduino Uno and some robotic car chassis parts. Ensure you read until the end to get the full step-by-step instructions of how this was designed and built.
obstacle avoidance robot
Obstacle Avoidance Robot: The Components and Materials Needed
Components
Quantity
Arduino Uno
1
Ultrasonic sensor HC-SR04
1
Motor Driver Shield
1
Servo Motor SG90 model
1
DC robotic Motor
4
Robotic Wheel
4
Chassis
2
LiPo Charging Module
1
LiPo Battery
4
LiPo Battery holder 4 battery rack
1
Wires
Assorted
Switch, button, gluestick and glue gun
1 each
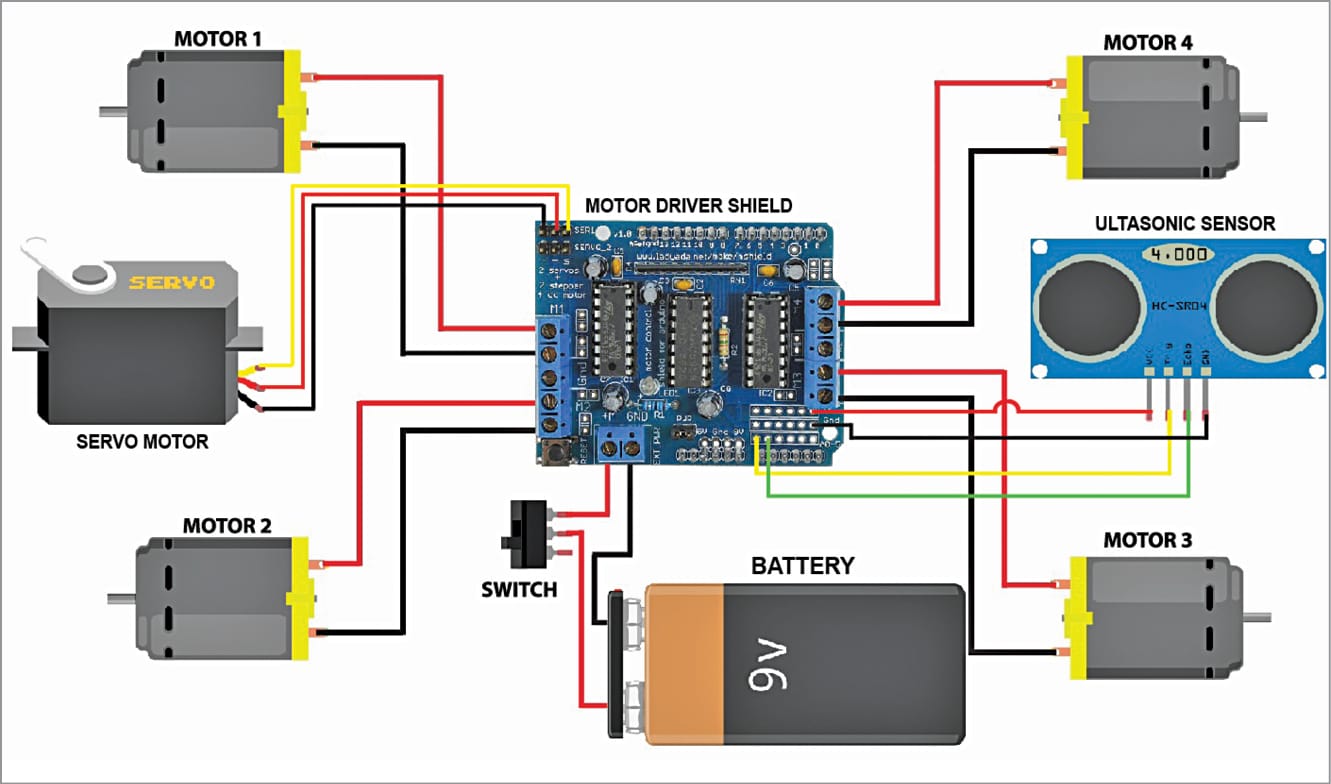
Obstacle Avoidance Robot: The Schematic Diagram
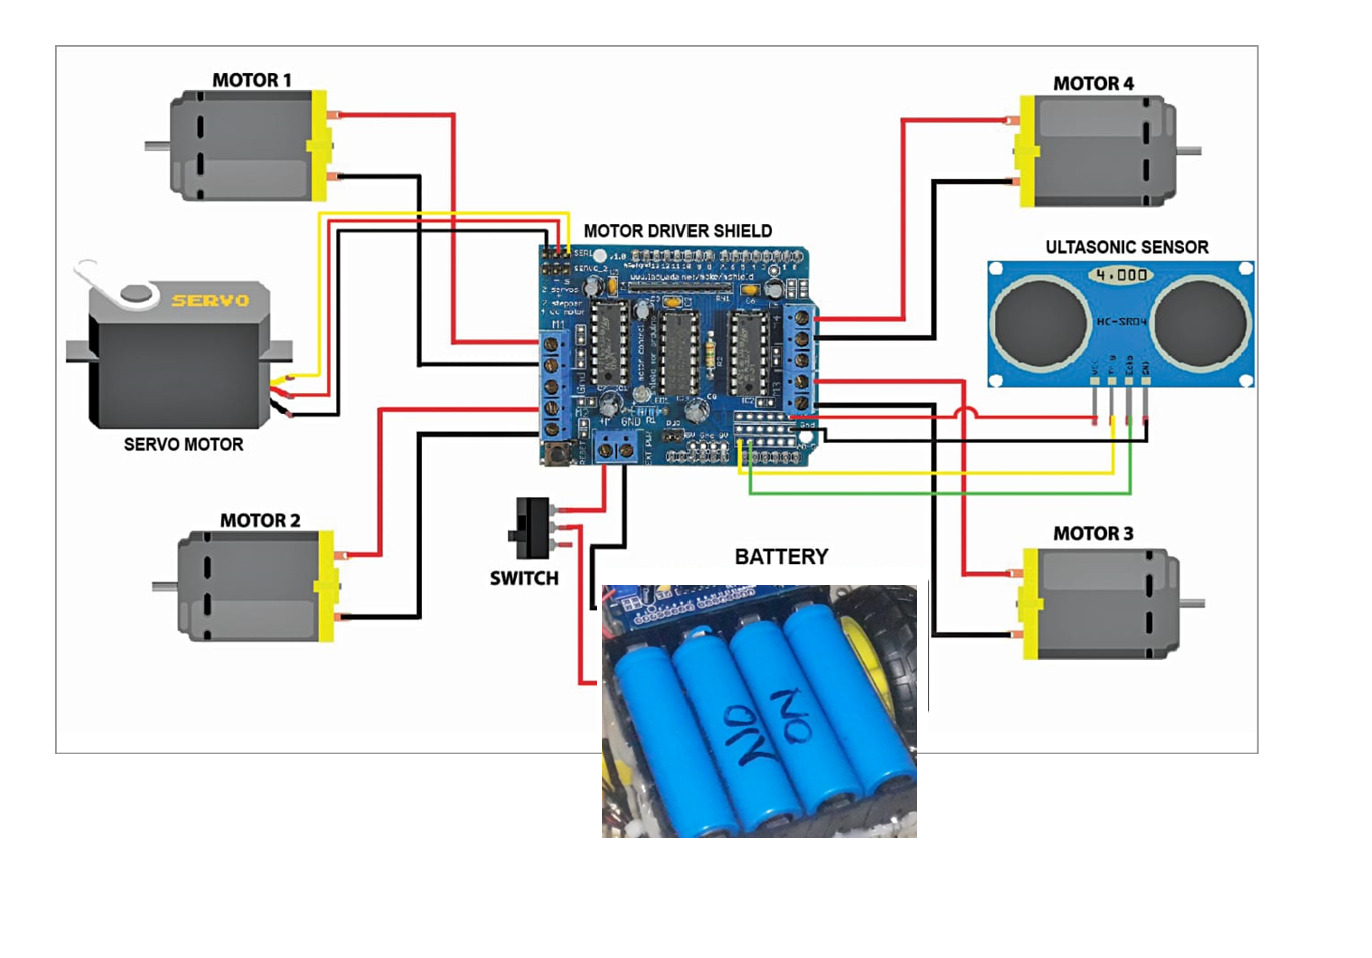
The above schematic diagram can be also found at the electronicsforyou website. The downside of this circuit diagram is that it doesn’t have a rechargeable battery and once the 9V battery power is depleted, you have to remove it and put another one. A modification of this circuit diagram is shown below.
The schematic diagram
Explanation Of Schematic Diagram
The schematic diagram uses the Arduino Uno ad the brain and development board for the project design. We used the Arduino motor driver shield. This supports DC motors, stepper motors, and also servo motor control. Since we will be controlling four (4) motors, the motor shield was the appropriate choice.
The motor shield just sits on the Arduino Uno board, making it very convenient. The ultrasonic sensor module helps us sense obstacles on the robot’s path. Whereas we used the switch to supply DC power into the system design. The servo motor is needed so that the robotic car can explore other view points that may not be obstructed. Hence, the ultrasonic sensor module is mounted on top of the servo motor gear.
Assembling The Obstacle Avoidance Robot Together
Obstacle avoidance robot: the components and parts
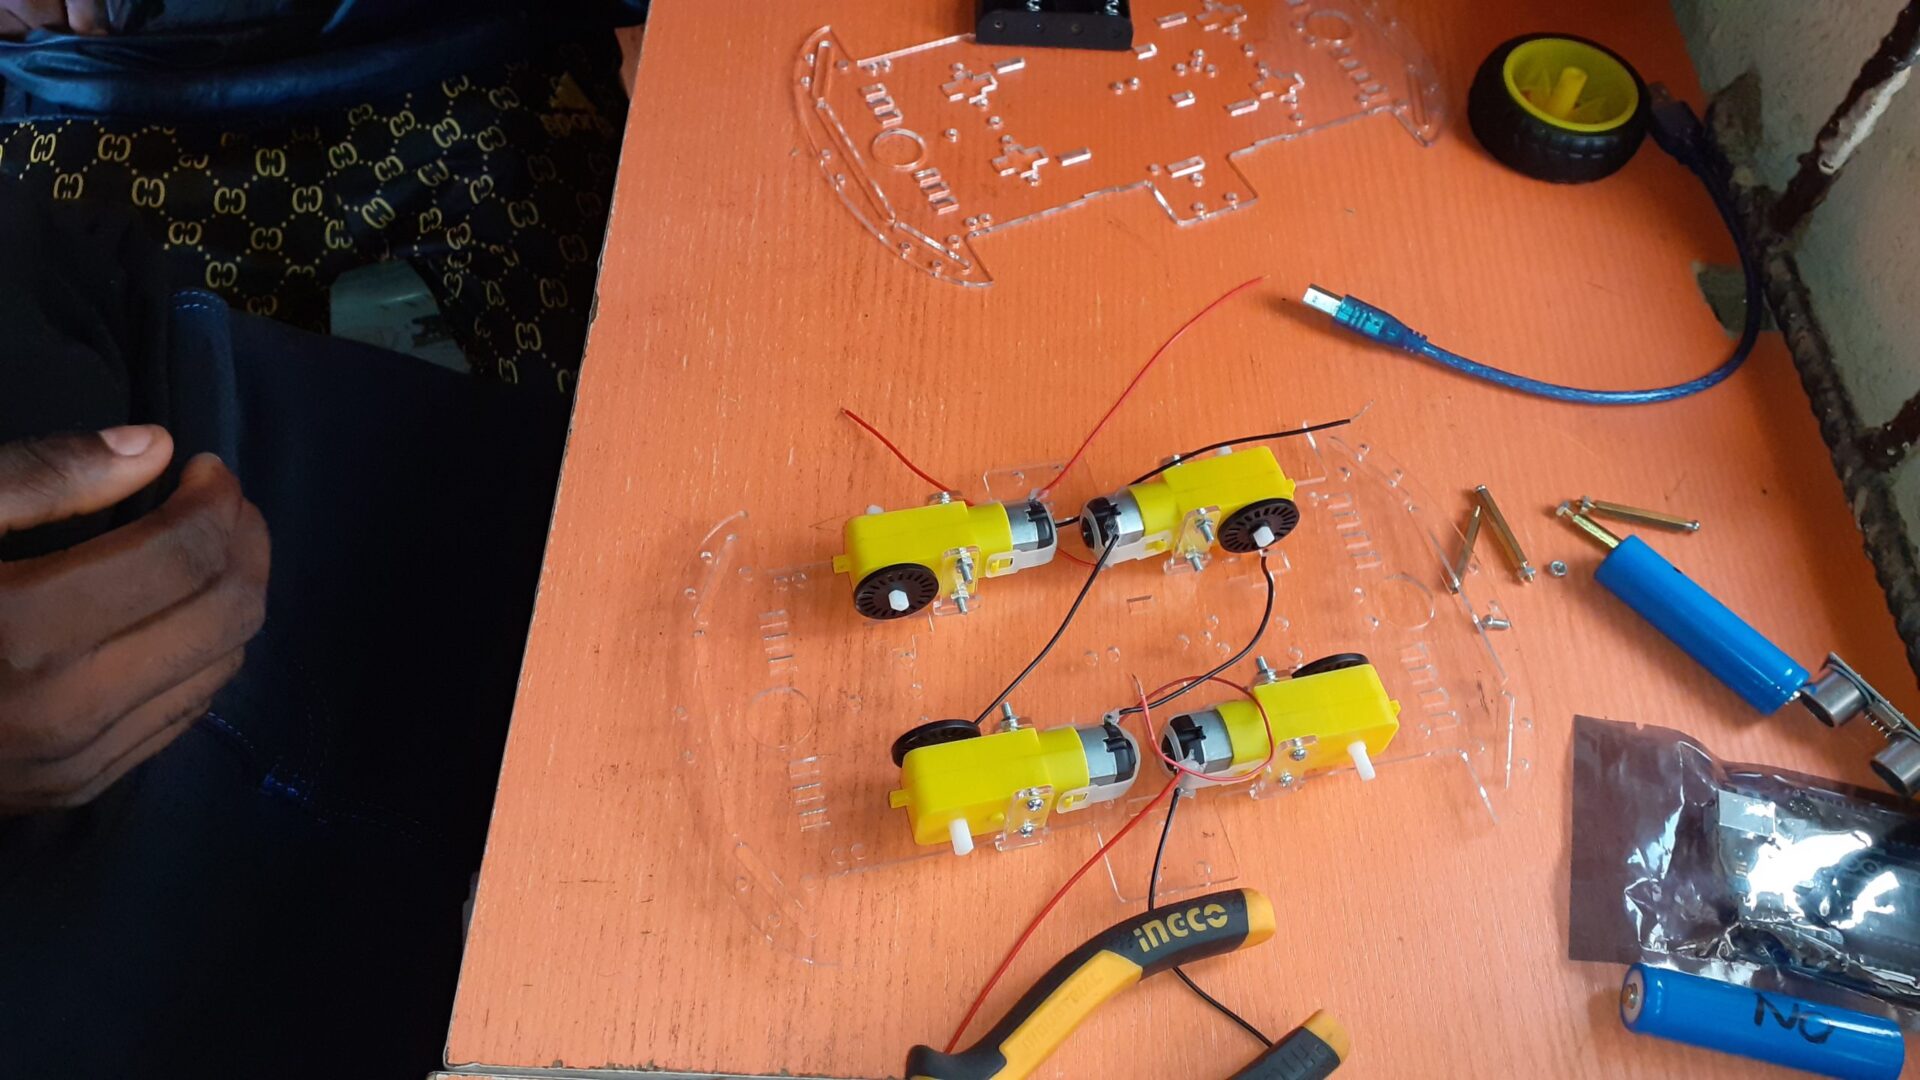
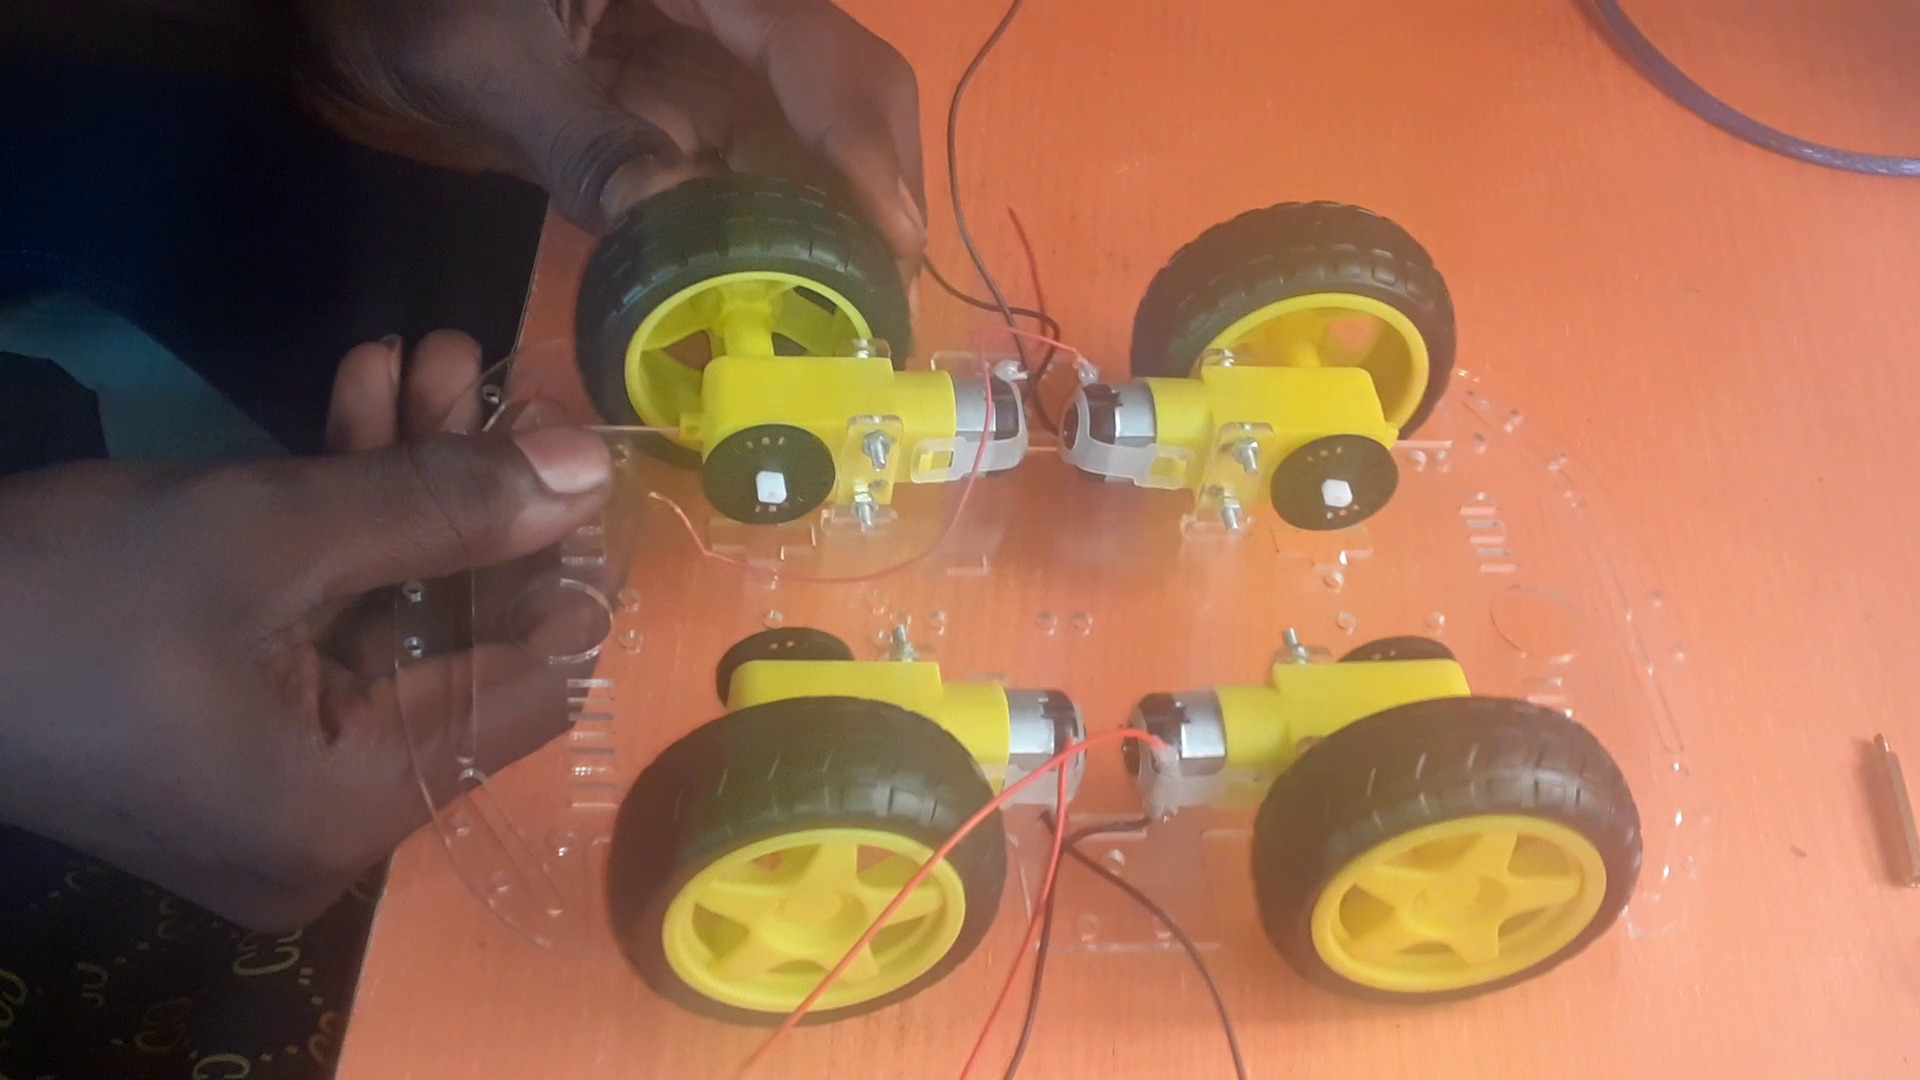
The robotic kit and its chassis were assembled as shown above. We removed all the robotic casing and assembled them using glue gun and gluestick solder. The robotic wheels were attached to the sides of the DC motor. Once this was done, it is time to connect the Arduino Uno and the motor shield together. The motor shield allowed us to make the same connections as we would using only the Arduino Uno, but it came with header pins so the connections were easier.
We used long nose plier to peel out the wires and soldered wires that need to be soldered. The LiPo batteries were aligned in a series connection with each battery outing a 4.2V at full charge and 3.7V at average. The resultant voltage was about 15V and the motor driver shield was able to use this voltage level.
Obstacle Avoidance Robot: The Arduino Source Code
#include <AFMotor.h>      //add Adafruit Motor Shield library
#include <Servo.h>        //add Servo Motor library

#define MAX_DISTANCE 60 // sets maximum useable sensor measuring distance to 60cm
#define MAX_SPEED 70 // sets speed of DC traction motors to 150/250 or about 70% of full speed - to get power drain down.
#define MAX_SPEED_OFFSET 20 // this sets offset to allow for differences between the two DC traction motors
#define COLL_DIST 30.00 // sets distance at which robot stops and reverses to 30cm
#define TURN_DIST COLL_DIST+20.00 // sets distance at which robot veers away from object

const int trigPin = 16; // Trigger Pin of Ultrasonic Sensor
const int echoPin = 17; // Echo Pin of Ultrasonic Sensor
long duration;
float distance;

AF_DCMotor leftMotor1(1, MOTOR12_1KHZ); // create motor #1 using M1 output on Motor Drive Shield, set to 1kHz PWM frequency
AF_DCMotor leftMotor2(2, MOTOR12_1KHZ); // create motor #2, using M2 output, set to 1kHz PWM frequency
AF_DCMotor rightMotor1(3, MOTOR34_1KHZ);// create motor #3, using M3 output, set to 1kHz PWM frequency
AF_DCMotor rightMotor2(4, MOTOR34_1KHZ);// create motor #4, using M4 output, set to 1kHz PWM frequency
Servo myservo;  // create servo object to control a servo

float leftDistance, rightDistance; //distances on either side
float curDist = 0.00;
String motorSet = "";
int speedSet = 0;

//-------------------------------------------- SETUP LOOP ----------------------------------------------------------------------------
void setup() {
  Serial.begin(9600);
  pinMode(trigPin, OUTPUT);
  pinMode(echoPin, INPUT);
  myservo.attach(10);  // attaches the servo on pin 10 (SERVO_1 on the Motor Drive Shield to the servo object
  myservo.write(90); // tells the servo to position at 90-degrees ie. facing forward.
  delay(2000); // delay for one seconds
 }
//------------------------------------------------------------------------------------------------------------------------------------

//---------------------------------------------MAIN LOOP ------------------------------------------------------------------------------
void loop() {
   myservo.write(90);  // move eyes forward
  delay(90);
  curDist = readPing();   // read distance
  if (curDist < COLL_DIST) {
    changePath();   // if forward is blocked change direction
    }
  moveForward();  // move forward
  delay(500);
 }
//-------------------------------------------------------------------------------------------------------------------------------------

void changePath() {
  moveStop();   // stop forward movement
  myservo.write(10);  // check distance to the right
    delay(500);
    rightDistance = readPing(); //set right distance
    delay(500);
    myservo.write(175);  // check distace to the left
    delay(700);
    leftDistance = readPing(); //set left distance
    delay(500);
    myservo.write(90); //return to center
    delay(100);
    compareDistance();
  }

  // find the longest distance
void compareDistance(){
//if left is less obstructed and more than 35cm
  if (leftDistance>rightDistance) {
    if(leftDistance > 35.00){
    turnLeft();
  }
  }

  //if right is less obstructed and above 35cm
  else if ((rightDistance>leftDistance) > 35.00) {
    turnRight();
  }

  //if they are equally obstructed
   else {
    turnAround();
  }
}


//-------------------------------------------------------------------------------------------------------------------------------------

int readPing() { // read the ultrasonic sensor distance
   digitalWrite(trigPin, LOW);
delayMicroseconds(2);
digitalWrite(trigPin, HIGH);
delayMicroseconds(10);
digitalWrite(trigPin, LOW);
duration = pulseIn(echoPin, HIGH);
distance = duration*0.034/2.0;
Serial.print("dist: ");
Serial.print(distance);
Serial.println(" cm");
//delay(300);
  return distance;
}

//-------------------------------------------------------------------------------------------------------------------------------------
void moveStop() {
  // stop the motors.
  leftMotor1.run(RELEASE);
  leftMotor2.run(RELEASE);
  rightMotor1.run(RELEASE);
  rightMotor2.run(RELEASE);
  }

//-------------------------------------------------------------------------------------------------------------------------------------
void moveForward() {
  Serial.println("MOVING FORWARD!");
    motorSet = "FORWARD";
    leftMotor1.run(FORWARD);      // turn it on going forward
    leftMotor2.run(FORWARD);      // turn it on going forward
    rightMotor1.run(FORWARD);     // turn it on going forward
    rightMotor2.run(FORWARD);     // turn it on going forward
  for (speedSet = 0; speedSet < MAX_SPEED; speedSet +=2)   {
    leftMotor1.setSpeed(speedSet);   // slowly bring the speed up to avoid loading down the batteries too quickly
    leftMotor2.setSpeed(speedSet);
    rightMotor1.setSpeed(speedSet);
    rightMotor2.setSpeed(speedSet);
    delay(5);
  }
}

//-------------------------------------------------------------------------------------------------------------------------------------
void moveBackward() {
  Serial.println("MOVING BACKWARD!");
    motorSet = "BACKWARD";
    leftMotor1.run(BACKWARD);     // turn it on going backward
    leftMotor2.run(BACKWARD);     // turn it on going backward
    rightMotor1.run(BACKWARD);    // turn it on going backward
    rightMotor2.run(BACKWARD);    // turn it on going backward
  for (speedSet = 0; speedSet < MAX_SPEED; speedSet +=2) // slowly bring the speed up to avoid loading down the batteries too quickly
  {
    leftMotor1.setSpeed(speedSet);
    leftMotor2.setSpeed(speedSet);
    rightMotor1.setSpeed(speedSet);
    rightMotor2.setSpeed(speedSet);
    delay(5);
  }
}
//-------------------------------------------------------------------------------------------------------------------------------------
void turnLeft() {
  Serial.println("MOVING LEFT!");
  motorSet = "LEFT";
  leftMotor1.run(FORWARD);      // turn motor 1 forward
  leftMotor2.run(FORWARD);      // turn motor 2 forward
  rightMotor1.run(BACKWARD);    // turn motor 3 backward
  rightMotor2.run(BACKWARD);    // turn motor 4 backward
  rightMotor1.setSpeed(speedSet+MAX_SPEED_OFFSET);
  rightMotor2.setSpeed(speedSet+MAX_SPEED_OFFSET);
  delay(500); // run motors this way for 1500
  motorSet = "FORWARD";
  leftMotor1.run(FORWARD);      // set both motors back to forward
  leftMotor2.run(FORWARD);
  rightMotor1.run(FORWARD);
  rightMotor2.run(FORWARD);
}
//-------------------------------------------------------------------------------------------------------------------------------------
void turnRight() {
  Serial.println("MOVING RIGHT!");
  motorSet = "RIGHT";
  leftMotor1.run(BACKWARD);      // turn motor 1 backward
  leftMotor2.run(BACKWARD);      // turn motor 2 backward
  leftMotor1.setSpeed(speedSet+MAX_SPEED_OFFSET);
  leftMotor2.setSpeed(speedSet+MAX_SPEED_OFFSET);
  rightMotor1.run(FORWARD);     // turn motor 3 forward
  rightMotor2.run(FORWARD);     // turn motor 4 forward
  delay(500); // run motors this way for 1500
  motorSet = "FORWARD";
  leftMotor1.run(FORWARD);      // turn it on going forward
  leftMotor2.run(FORWARD);      // turn it on going forward
  rightMotor1.run(FORWARD);     // turn it on going forward
  rightMotor2.run(FORWARD);     // turn it on going forward
}
//-------------------------------------------------------------------------------------------------------------------------------------
void turnAround() {
  Serial.println("MOVING AROUND!");
  motorSet = "RIGHT";
  leftMotor1.run(FORWARD);      // turn motor 1 forward
  leftMotor2.run(FORWARD);      // turn motor 2 forward
  rightMotor1.run(BACKWARD);    // turn motor 3 backward
  rightMotor2.run(BACKWARD);    // turn motor 4 backward
  rightMotor1.setSpeed(speedSet+MAX_SPEED_OFFSET);
  rightMotor2.setSpeed(speedSet+MAX_SPEED_OFFSET);
  delay(1700); // run motors this way for 1700
  motorSet = "FORWARD";
  leftMotor1.run(FORWARD);      // set both motors back to forward
  leftMotor2.run(FORWARD);
  rightMotor1.run(FORWARD);
  rightMotor2.run(FORWARD);
}
Explanation of Arduino Sketch
The Arduino sketch written for the obstacle avoidance robot project has a lot of comment lines to explain what each line of code means. However, the source code made use of two importation of libraries: the Adafruit library and the servo motor library.
Testing The Project Design
The project design worked as expected. It was able to detect obstacles and navigate around them by following or taking the path that doesn’t have such obstacle. When the obstacle avoidance robot approaches a wall, it was a “U” turn and retraces its footsteps. The robot is smart enough to move on its own without human guidance.
Conclusion
We have designed, programmed and constructed an obstacle avoidance robotic car that has high degree of accuracy. It can detect any obstacle along its path and turn away from it or go around it. The project design was impressive and we think it is worth taking a shot at.
There’s a chance about the future solar energy that the sun and other low-tech elements like pebbles will be used to create the next generation of sustainable energy technologies. Which is quite interesting, imagine, rocks as solar energy collectors.
By storing solar heat using a novel technique called concentrated solar power, food can be dried or energy can be produced. Some soapstone and granite samples from Tanzania, according to a team publishing in ACS Omega, have high energy densities and are stable even at high temperatures, making them ideal for storing this solar heat.
future solar energy
When not in use, energy is frequently stored in huge batteries, but these can be pricey and consume a lot of resources to produce. Thermal energy storage (TES), a less sophisticated option, stores energy as heat in a liquid or solid, such as water, oil, or rock. The heat can drive a generator to generate electricity when it is released. Rocks like granite and soapstone, which are widespread and specially created under great temperatures, may be suitable TES materials.
However, their properties can vary greatly based on where in the world they were formed, possibly making some samples better than others. In Tanzania, the Craton and Usagaran geological belts meet, and both contain granite and soapstone. So, Lilian Deusdedit Kakoko, Yusufu Abeid Chande Jande and Thomas Kivevele from Nelson Mandela African Institution of Science and Technology and Ardhi University wanted to investigate the properties of soapstone and granite found in each of these belts.
The team collected several rock samples from the belts and analyzed them. The granite samples contained a large amount of silicon oxides, which added strength. However, the Craton granite contained other compounds, including muscovite, which are susceptible to dehydration and could make the rock unstable at high temperatures.
The soapstone contained magnesisite, which gave it a high density and heat capacity. Both soapstone samples and the Usagaran granite remained solid at temperatures over 1800 degrees Fahrenheit, but the Craton granite crumbled. Furthermore, the granite proved less likely to release its heat-stored energy than the soapstone. All things considered, the Craton soapstone performed the best as a TES, effectively absorbing, storing, and transmitting heat while keeping good chemical stability and mechanical strength.
The other rocks, however, would be more appropriate for a TES use requiring less energy, like a sun dryer. These samples, according to the researchers, show good potential as a sustainable energy storage material, even if more testing is required.
Conclusion
Having a breakthrough of making rocks as solar energy collectors would mean a huge deal and so much possibilities for the future generations. Let us know your thoughts on these in the comment sections. Thank you.
A two-seat electric-battery-powered helicopter made a quiet landing on the runway at the Paris Air Show following a 15-minute flight.
These cutting-edge “flying taxis” are among the highlights of this year’s aerospace industry gathering as they get closer to the time when the general public can use them.
More than ten years after its initial test flight, the German company Volocopter’s VoloCity will make its next visit during the Paris Olympic Games in 2024, where it hopes to transport spectators throughout the French metropolis.
The 18-rotor aircraft can fly at a top speed of 110 kilometers per hour (68 miles per hour), and it can accommodate a pilot and a passenger.
The good news is that flying is relatively easy. Its computerized flight control system is quite sophisticated, according to VoloCity pilot Paul Stone, who previously tested fighter jets for the Royal Navy of Great Britain.
Helicopter and airplane pilots with extensive experience will receive training to fly the VoloCity, he said.
The irony is that because an airplane is so much easier to fly than, example, a helicopter, helicopter pilots will have to relearn a lot of really sophisticated abilities.
In order to prepare for the Olympics, Volocopter has been performing test flights around Paris for more than a year.
The business has been collaborating on the project with Groupe ADP, which runs the airports in Paris, RATP, the government of the Ile-de-France region, and other parties.
More than 20 flights covering 200 kilometers, according to ADP CEO Edward Arkwright, have taken place.
on addition to a heliport near Versailles and a “vertiport” set up on a barge on the Seine river in southeast Paris, the air taxi will operate between Paris Charles de Gaulle Airport and adjacent Paris-Le Bourget Airport.